I’m Hongzhe Bi, a second-year Matser student advised by Professor Jun Zhu in the TSAIL, Department of Computer Science and Technology, Tsinghua University, and co-advised by Zhizhong Su at Horizon Robotics.I graduated from Class of Artificial Intelligence, Beijing University of Posts and Telecommunications with a bachelor’s degree.
My Research Interests include General Embodied Intelligence, Cross-Embodied Robot Foundation Model and Bimanual Dextrous Manipulation.
Publications
General Embodied Intelligence
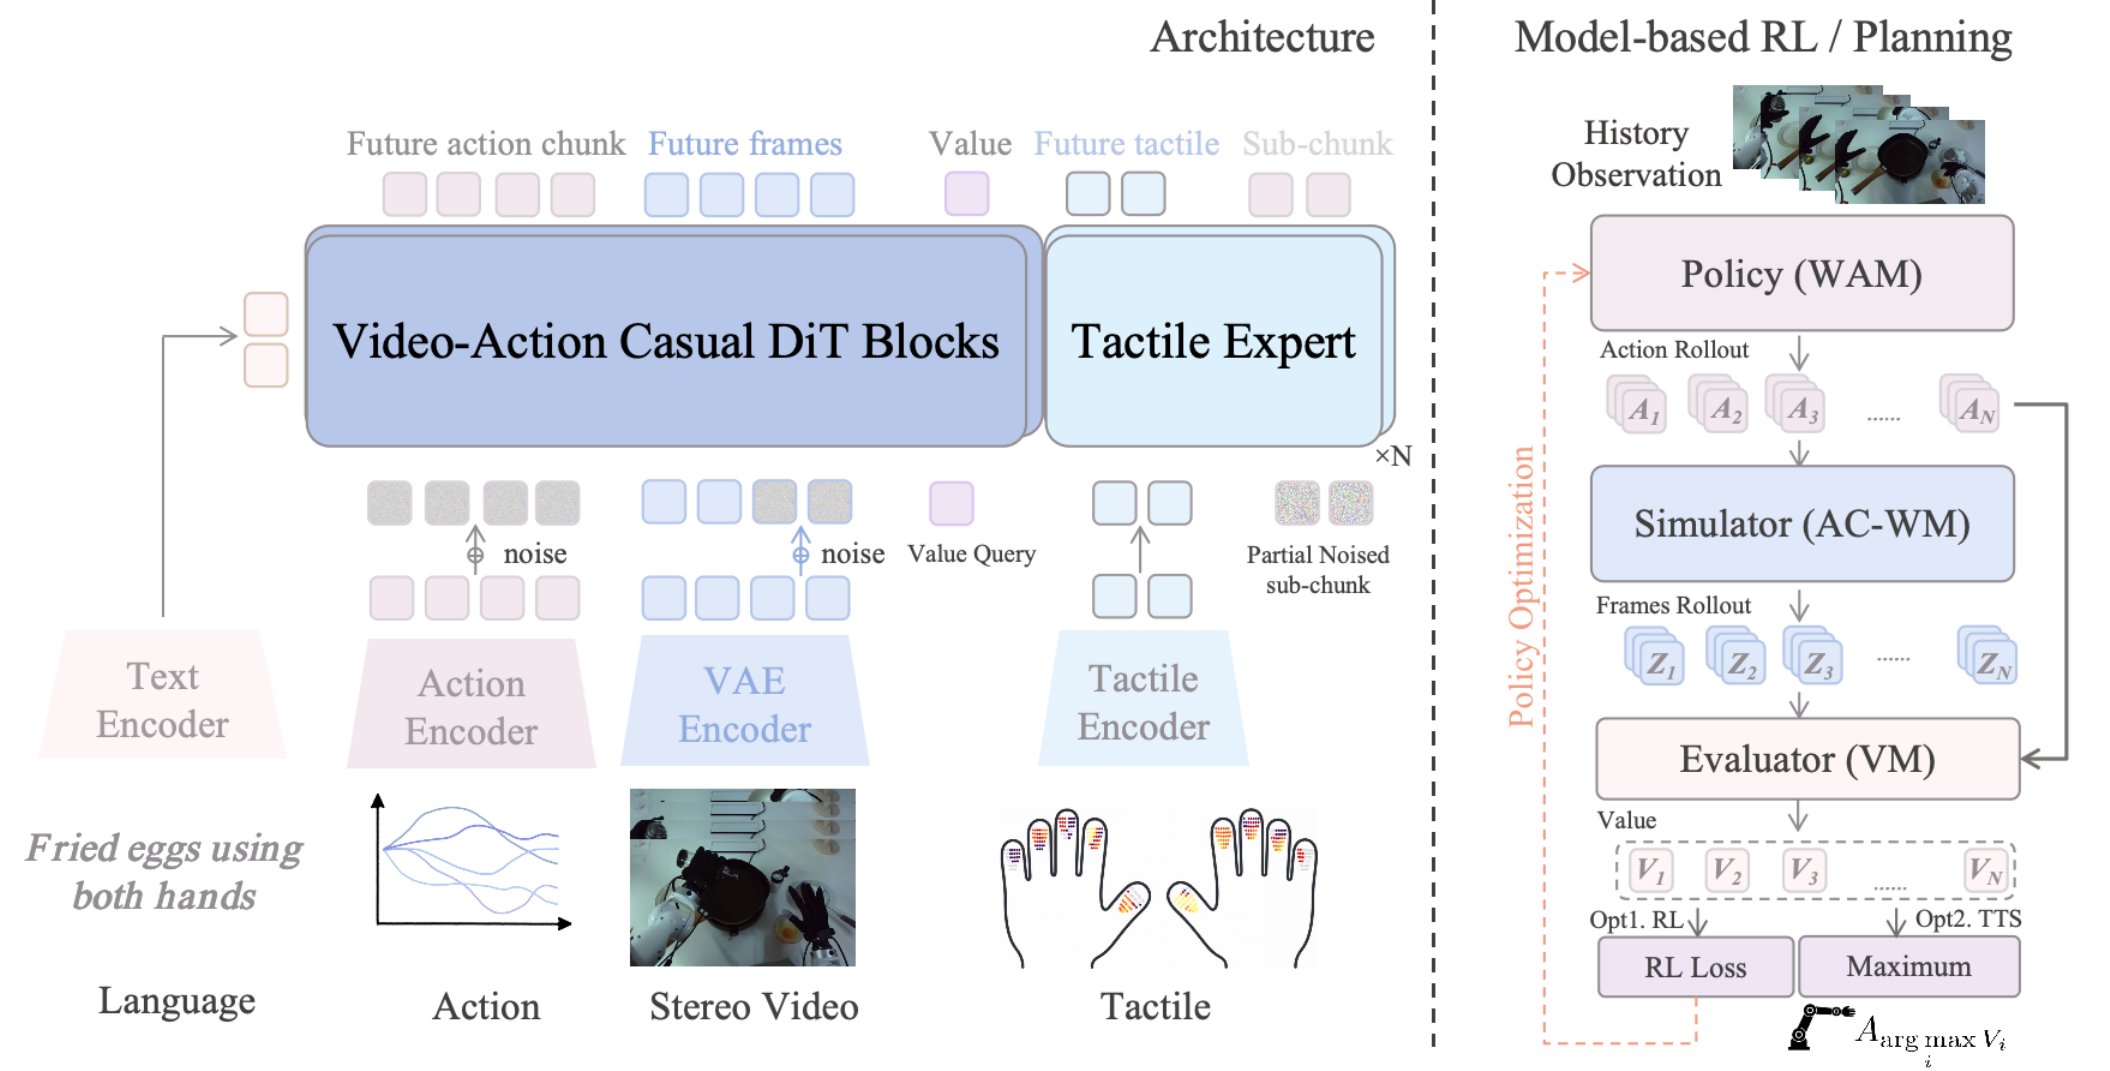
Motus2: A Self-Evolving General World Model for Dexterous Manipulation
Hongzhe Bi, Zihao Zhou, Yihang Tang, Jingrui Pang, Shuhe Huang, Haitian Liu, Runqing Wang, Shuai Huang, Yichen Wang, Yiming Cheng, Ruowen Zhao, Zhenghua Li, Hengkai Tan, Xiaolong Liu, Jinhui Wan, Jiabao Liu, Min Zhao, Fan Bao, Jun Zhu
- Motus2 is the first fully multimodal General World Model for high-DoF dexterous manipulation, integrating vision, language, action, and touch. It is the first to realize closed-loop self-evolution with one shared model serving as a policy, simulator, and evaluator. Expert demonstrations supervise action learning, while failed and suboptimal interactions support dynamics and value learning. Data scaling spans approximately 130,000 raw hours of monocular and stereo egocentric recordings, followed by robot-domain adaptation at the hundred-hour scale. The model further explores long-context modeling and adds tactile feedback for contact-aware control. Together, egocentric data scaling and closed-loop general world model scaling provide a general path toward self-evolving dexterous manipulation.
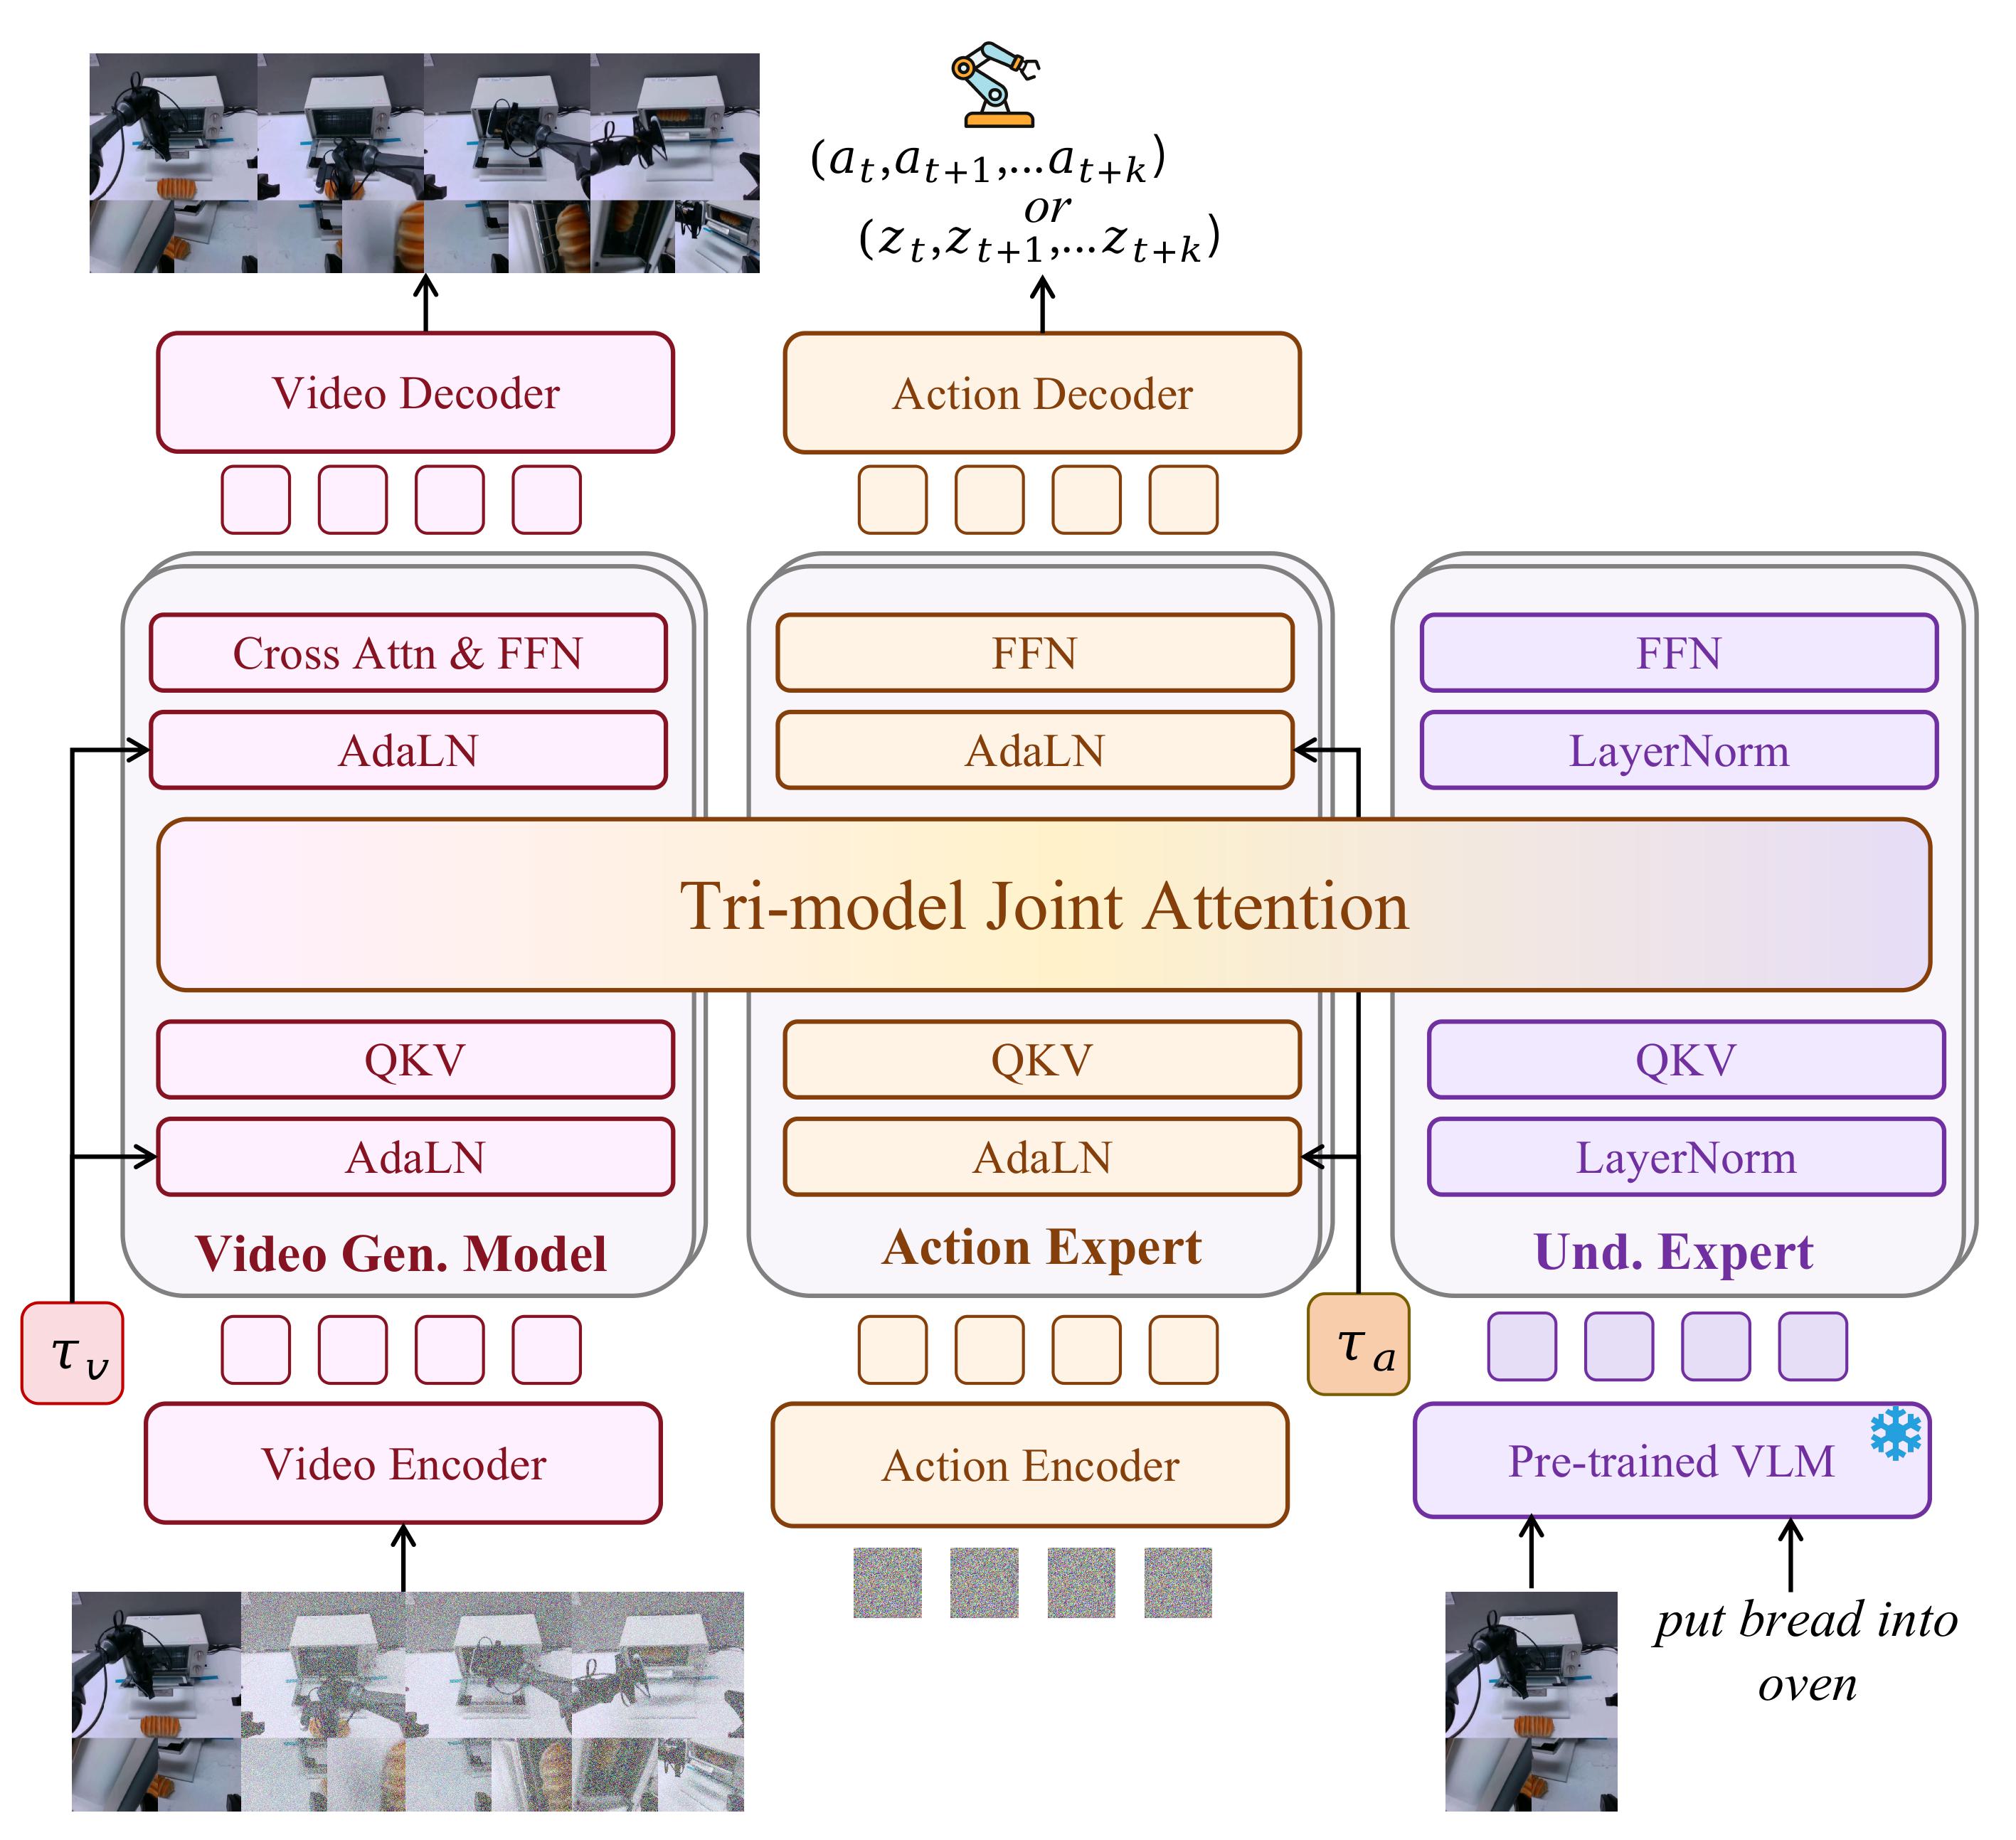
Motus: A Unified Latent Action World Model
Hongzhe Bi, Hengkai Tan, Shenghao Xie, Zeyuan Wang, Shuhe Huang, Haitian Liu, Ruowen Zhao, Yao Feng, Chendong Xiang, Yinze Rong, Hongyan Zhao, Hanyu Liu, Zhizhong Su, Lei Ma, Hang Su, Jun Zhu
- Motus is among the earliest world-action models to unify understanding, imagination, and action through joint video-action modeling. It integrates pretrained vision-language and video-generation models with an action expert, allowing one shared model to switch flexibly across five prediction and control modes. Motion-based latent actions enable large-scale action pretraining from human videos and heterogeneous robot experience. Simulation and real-world experiments demonstrate that unifying these capabilities and pretrained priors improves downstream robot manipulation over strong contemporary baselines.
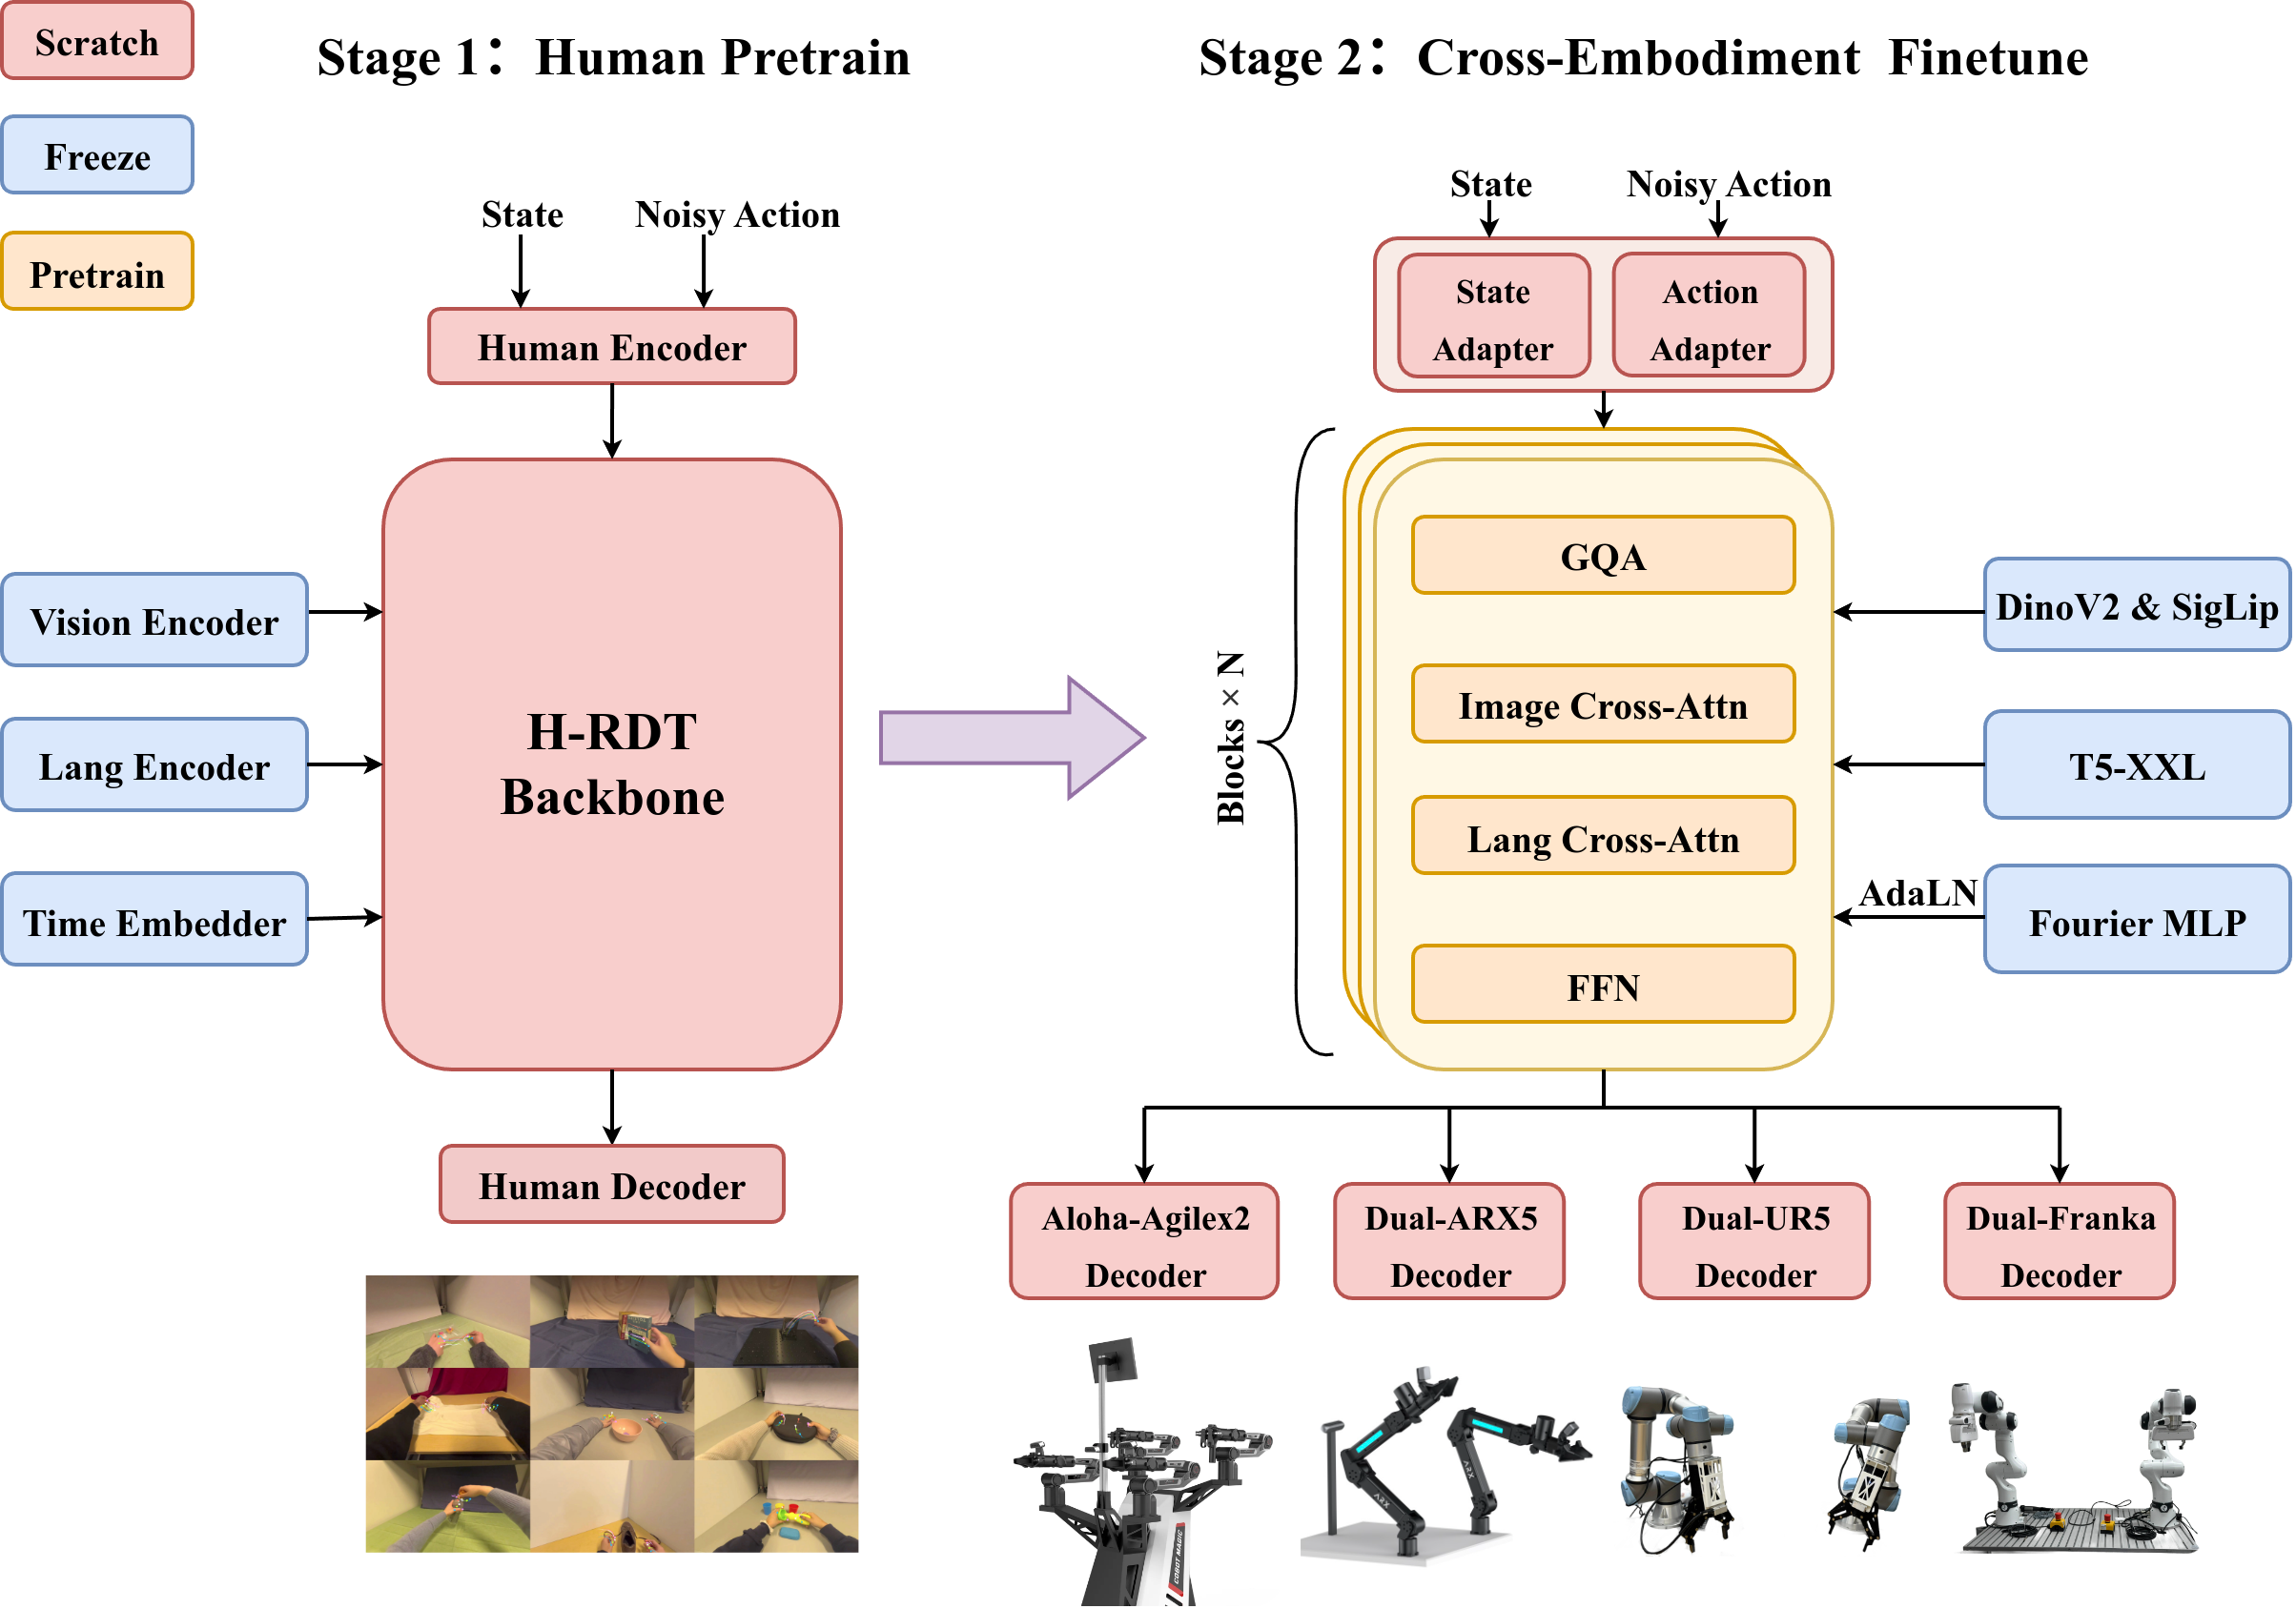
H-RDT: Human Manipulation Enhanced Bimanual Robotic Manipulation
Hongzhe Bi, Lingxuan Wu, Tianwei Lin, Hengkai Tan, Zhizhong Su, Hang Su, Jun Zhu
- H-RDT is among the first studies to establish large-scale egocentric human data as a foundation for bimanual robot manipulation, addressing the scarcity of robot demonstrations. It pretrains on human videos with paired 3D hand poses, then transfers these manipulation priors to diverse robots through cross-embodiment fine-tuning. Simulation and real-world evaluations demonstrate improvements over contemporary baselines, including Pi0 and RDT, together with few-shot learning and robustness across tasks. The work has also informed the development of embodied manipulation foundation models at Horizon Robotics.

Xuewu Lin, Tianwei Lin, Yun Du, Hongyu Xie, Yiwei Jin, Jiawei Li, Shijie Wu, Qingze Wang, Mengdi Li, Mengao Zhao, Ziang Li, Chaodong Huang, Hongzhe Bi, Lichao Huang, Zhizhong Su
- HoloBrain-0 is a comprehensive VLA framework that bridges foundation models with reliable real-world deployment. By explicitly incorporating embodiment priors (kinematics & camera parameters), we achieve SOTA manipulation performance on both simulation and real-world benchmarks. We open-source the full ecosystem, including the RoboOrchard infrastructure, to democratize scalable robot learning.
Other Directions
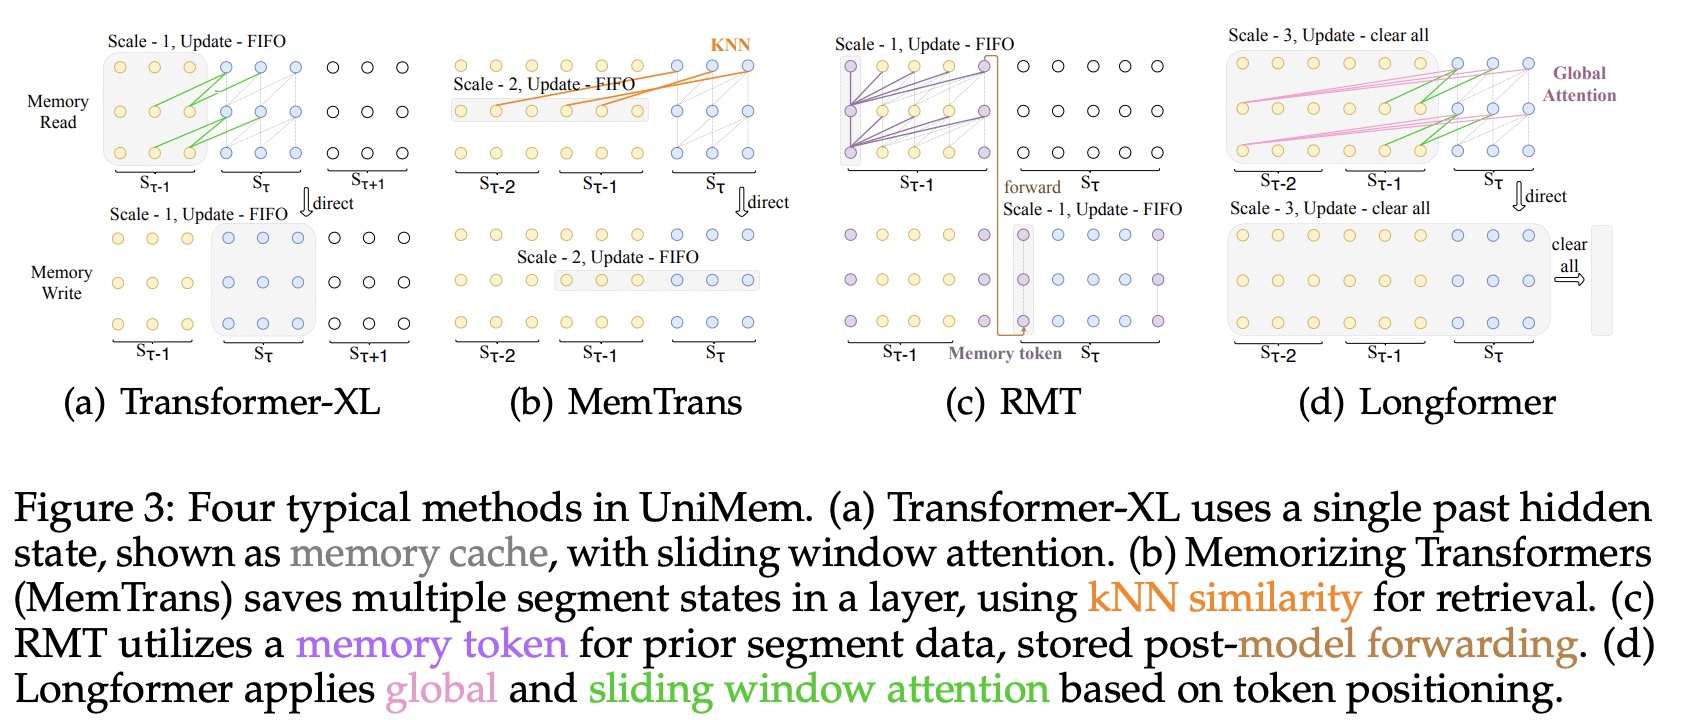
UniMem: Towards a Unified View of Long-Context Large Language Models
Junjie Fang, Likai Tang, Hongzhe Bi, Yujia Qin, Si Sun, Zhenyu Li, Haolun Li, Yongjian Li, Xin Cong, Yankai Lin, Yukun Yan, Xiaodong Shi, Sen Song, Zhiyuan Liu, Maosong Sun
- UniMem unifies long-context language modeling from the perspective of memory augmentation, turning isolated methods into a common framework for systematic analysis and design. It reformulates 16 methods across memory management, writing, reading, and injection, and analyzes representative approaches to reveal their design principles and complementary strengths. This analysis guides UniMix, which integrates those strengths to improve long-context processing and reduce perplexity relative to baselines. The work provides a systematic basis for understanding existing approaches and designing more effective memory mechanisms for long-context language models.
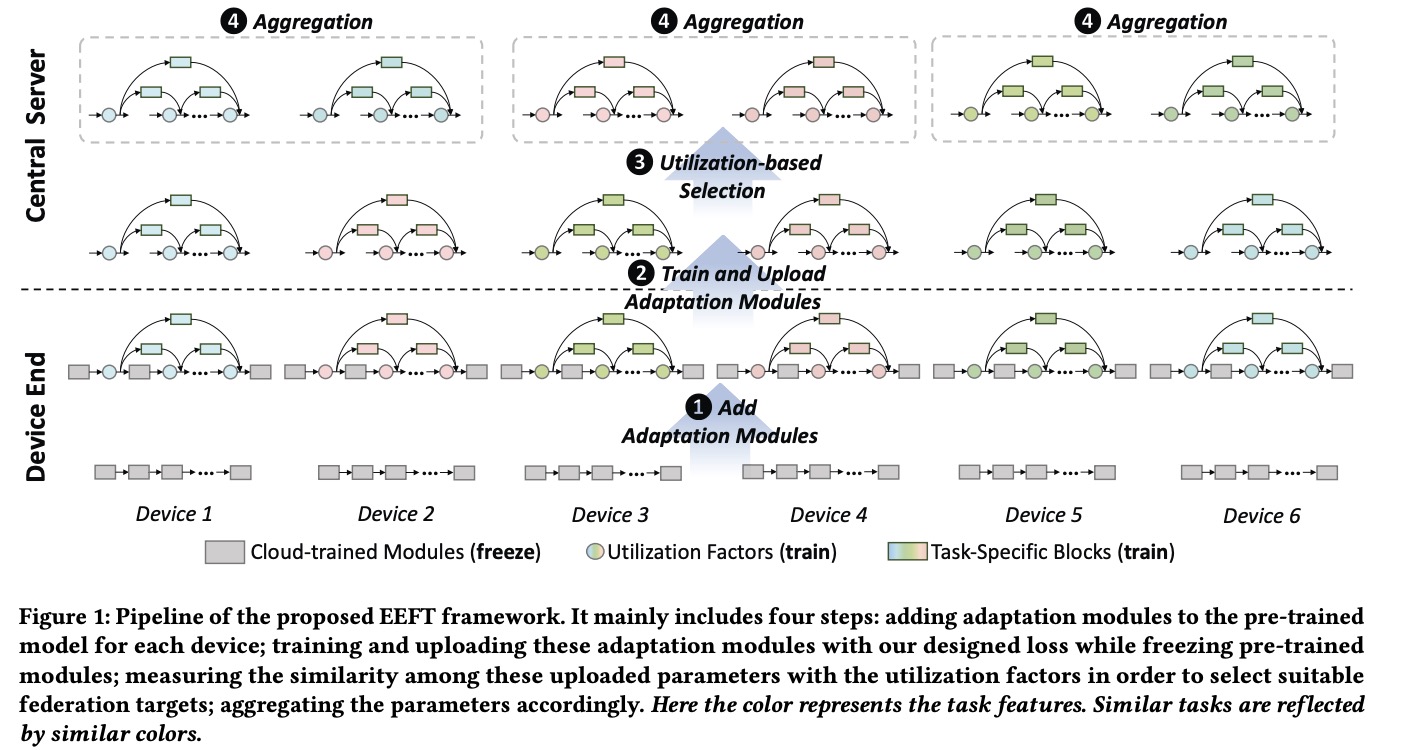
Beyond Fine-Tuning: Eficient and Efective Fed-Tuning for Mobile/Web Users
Bingyan Liu, Yifeng Cai, Hongzhe Bi, Ziqi Zhang, Ding Li, Yao Guo, Xiangqun Chen
- This paper extend the local-user fine-tuning to multi-user fed-tuning with the help of Federated Learning (FL).
Honors and Awards
- 2025.06 First place in Real-world Track and Second place in Simulation Track of RoboTwin Dual-Arm Collaboration Challenge@CVPR2025
Teaching
- 2026 Spring, TA in Statistical Learning Theory and Applications, instructed by Prof. Jun Zhu
Educations
- 2024.09 - now, Master, TSAIL, Department of Computer Science and Technology, Tsinghua University
- 2020.09 - 2024.06, Undergraduate, School of Artificial Intelligence, Beijing University of Posts and Telecommunications(BUPT)
- 2014.09 - 2020.06, High School, Beijing 101 Middle School
Internships
- 2024.10 - 2026.03, Horizon Robotics Lab
- 2024.04 - 2024.08, D-Robotics
- 2023.10 - 2024.01, ModelBest